From Well Clear to Well Separation?
Why a New Approach?
What Is Well Separation?
How Well Separation Works
Four-Stage Cooperative DAA Framework
Real-Flight Demonstration
Enabling Technology - UAAN
Next Step - Toward Cooperative Airspace
Q&A
From Well Clear to Well Separation?
From Well Clear to Well Separation?
A Cooperative DAA Framework for High-Density Low-Altitude Airspace

Future airspace will be shared by drones, UAM, and crewed aircraft.
However, we have not yet fully ensured the safety of drone operations.
As a first step toward safer drone operations, we propose a new concept called
Well Separation.
Why a New Approach?
Why a New Approach?
Why Do We Need a New Approach for Low-Altitude Operations?
Well Clear (WC) was designed for aircraft. Aircraft have enough space in the sky to maintain adequate separation. The figure on the lower right shows WC applied to drones. With only about three drones, they can maintain WC effectively.


However, as shown in the figure below, when drone density increases, the WC areas begin to overlap. WC itself still works, but increasing drone density creates a new challenge.

So, we developed a different concept to address this challenge. We call it Well Separation.
What Is Well Separation?
What Is Well Separation?
To explain WS, let me use an analogy with cars.

These two cars are in a very dangerous situation. Because they do not know each other's intentions, continuing to approach each other is extremely risky.
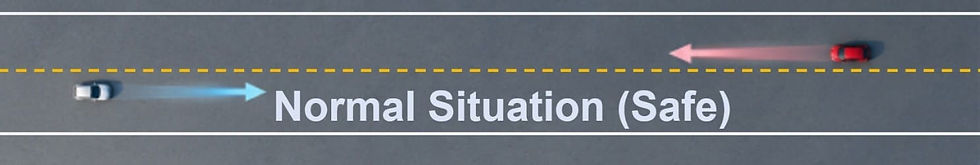
But when there are lanes, the situation is different. We know that the other car will stay in its own lane. In other words, we know the other driver's intention. That is what makes the situation safe.

We can apply the same idea to drones. By sharing their intentions — such as position, heading, and waypoints — drones can fly safely, much like cars on a road.
In other words, WS means maintaining continuous safe separation by sharing intentions between drones.
How Well Separation Works
How Well Separation Works
1. The drone begins its flight.
2. During flight, the drone receives information from other drones through direct drone-to-drone (D2D) communication.
3. It analyzes the intentions of the other drones and detects any separation violation.
For example, if we set the minimum separation distance to 15 meters, any drone predicted to come within 15 meters is considered a separation violation. A potential separation violation is typically detected from more than 1 kilometer away.
4. When a potential separation violation is detected, the drone sends a negotiation message to the other drone.
The negotiation may involve changing the flight path, speed, or altitude.
5. Through this negotiation, the drones resolve the potential separation violation well in advance, while they are still far apart.
6. The drones approach each other after safe separation has already been established.
7. As they get closer, they continuously monitor whether the established separation is being reduced or lost.
8. The drones safely pass each other while maintaining safe separation.
Direct D2D Communication → Risk Prediction → Drone-to-Drone Negotiation → Path/Speed Adjustment → Continuous MSD Maintenance
Well Separation is not about avoiding a sudden collision. It is a normal flight state in which drones detect potential risks early and maintain safe separation well before they get close to each other.
Separate Early. Stay Separated.
* Air-to-Air communication allows drones to exchange information directly without relying on base stations. For example, ISO/IEC 4005 UAAN (Unmanned Aircraft Area Network) is an international communication standard that supports direct drone-to-drone communication.
Four-Stage Cooperative DAA Framework
Four-Stage Cooperative DAA Framework
We propose a new DAA framework for drones.
Step 1 | Step 2 | Step 3 | Step 4 |
|---|---|---|---|
Pre-Separation | WELL SEPARATION | WS Recovery | Last Resort |
Plan separation before potential conflicts develop. | Continuously maintain safe separation from other drones through shared intent. | Restore separation when Well Separation is degraded. | Autonomously Perform emergency maneuvers to prevent collision. |
PLAN IT! | MAINTAIN IT! | RESTORE IT! | Escape if necessary! |
Stage 1: Pre-Separation
Pre-Separation is similar to Stage 1 of DAA for crewed aircraft. Separation is planned in advance before the flight begins.
Stage 2: Well Separation
Well Separation means establishing and maintaining safe separation early, while the drones are still far apart. WS is not performed only in an emergency. It is continuously maintained during normal flight. Therefore, potential risks are detected and resolved in advance.
Stage 3: WS Recovery
WS Recovery is performed when Well Separation is degraded or lost. A drone can restore WS by itself or through renegotiation with other drones.
Stage 4: Last Resort
Last Resort is an action in which a drone independently tries to maximize its separation from other drones. This may include hovering, climbing, or other emergency maneuvers.
Real-Flight Demonstration
Real-Flight Demonstration
A: path change
We have demonstrated WS in actual flight tests. The first method for achieving WS is path adjustment. The drones detect a potential conflict and negotiate their flight paths.

The drones then change their paths according to the negotiation and continuously monitor the predicted separation distance. The purple graph below initially shows zero. In other words, a separation distance of 0 meters means a collision. After the negotiation, you can see that the predicted separation distance remains at 15 meters.


This figure shows the screen of our ground monitoring program. The program uses drone broadcast information received by a ground receiver to display the drones’ positions and flight paths.
The graph in the upper-left corner shows actual flight data, confirming that the required MSD is continuously maintained.

This photo shows the actual flight test. As the drones pass each other, you can see that the minimum separation distance is 15 meters. You can watch the full video by clicking the link below.
https://www.youtube.com/watch?v=XkJVVL1JUBc
B: Speed change
The second method for achieving WS is speed adjustment. The drones detect a potential conflict and negotiate their speeds.
In this demonstration, we had three drones fly toward the same intersection point. On the ground monitoring program, you can see all three drones approaching the same intersection.
As soon as the drones begin flying, they negotiate and adjust their speeds. Due to the limited size of the test site, the drones first hover about 200–250 meters from the intersection and then begin flying simultaneously.

This screen shows Drone 2 passing through the intersection and maintaining a minimum separation distance of 15 meters from Drone 3. In the upper-left corner, you can see three graphs showing the minimum separation distances between the three drones. All three continuously maintain a separation distance of at least 15 meters.
The photo below shows the actual flight test.

You can watch the video of this demonstration by clicking the link below.
https://www.youtube.com/watch?v=bY-RkWiFBH8
We plan to continue uploading more flight demonstration videos. If you are interested, please subscribe to the ToBScommunication YouTube channel and turn on notifications.
C: Altitude change
Currently, the altitudes of the drones are already separated to some extent for safe demonstration. Therefore, altitude change demonstrations will be conducted in the future.
Enabling Technology - UAAN
Enabling Technology — UAAN
For communication to achieve WS, we use UAAN (Unmanned Aircraft Area Network). UAAN is an ISO/IEC 4005 communication standard developed specifically for drone communication. The development of UAAN was led by Dr. Hyun-gu Hwang, CEO of ToBScommunication.
The test drones communicate directly with each other through UAAN without relying on base stations. Using UAAN, the drones can negotiate directly with one another.
The broadcast information includes each drone’s position, speed, heading, and waypoint information. Currently, the drones broadcast this information once per second.
UAAN has a communication range of approximately 3 to 5 kilometers. Within this range, approximately 400 drones can communicate with one another.
Because UAAN is a distributed direct communication system without base stations, it does not depend on the network infrastructure that can cause system-wide communication outages in LTE. The system is also designed to handle temporary packet loss or communication errors.
Next Step - Toward Cooperative Airspace
Next Step — Toward Cooperative Airspace

From Cooperative Separation to Cooperative Airspace
We believe this concept can go beyond drone-to-drone operations. In mixed airspace, crewed aircraft could gain earlier awareness of drones, and drones could gain earlier awareness of crewed aircraft. This could create another layer of safety between crewed and uncrewed aviation.
Earlier Awareness → Earlier Separation → Safer Mixed Airspace
Our goal is not simply to connect drones.
Our goal is to help build a cooperative safety framework for future low-altitude airspace.
Q&A
Q & A
1. What exactly is Well Separation?
Well Separation means maintaining a safe distance before a situation becomes a collision risk. The goal of WS is early separation, not last-second collision avoidance.
2. How is Well Separation different from collision avoidance?
Collision avoidance is a relatively late-stage safety measure. Well Separation works much earlier, allowing drones to maintain safe separation while there is still enough time and space.
3. Why do you start separation so early?
When drones respond early, only small adjustments to their paths or speeds are needed. This is safer and more efficient than making sudden maneuvers just before a collision.
4. What actually happens when two drones approach each other?
The drones detect a potential conflict early, check each other's flight intentions, and negotiate how to maintain separation. Once safe separation is established, they continue their original missions.
5. Do the drones only know each other's current positions?
No. They share not only their positions, but also their speed, heading, altitude, and planned path information. So they know not only where the other drone is now, but also where it is going.
6. How far away can the drones predict a potential collision?
Drones can predict a potential collision when they are about 1 to 2 kilometers apart. For encounters between crewed aircraft and drones, we believe prediction may be possible from about 3 to 4 kilometers away.
7. How do the drones determine whether there is a collision risk?
They use shared information such as position, speed, heading, and planned paths to predict their future trajectories and determine whether safe separation may be lost.
8. How do two drones decide which one should avoid the other?
Based on predefined rules, the drones communicate directly and negotiate how to maintain separation. The important point is that both drones know what the other drone is going to do.
9. Doesn't a central control system make the avoidance decision?
No. Separation and avoidance decisions are made in a distributed manner. Each drone makes its own decisions using information received directly from nearby drones.
10. What happens in a head-on encounter?
The two drones detect the potential conflict early and negotiate their separation maneuvers. We demonstrated this process in our head-on flight test.
11. What happens when the paths of two drones cross?
The drones predict the intersection of their paths and negotiate separation before reaching the crossing point. If necessary, one or both drones adjust their paths.
12. Does only one drone maneuver, or can both drones maneuver?
Both are possible, depending on the situation. The important point is that the drones do not avoid each other independently. They communicate, know what the other drone will do, and move cooperatively.
13. Do the drones return to their original missions after separation?
Yes. Once safe separation is established, they can automatically return to their original flight paths and continue their missions.
14. How do you verify the minimum separation distance during the demonstration?
We record the actual flight data and use our replay program to review the trajectories of the drones and verify the minimum separation distance.
15. How do you determine whether the demonstration was successful?
After the negotiation, we check whether the required separation was maintained, whether the coordinated maneuvers were performed correctly, and whether the drones safely returned to their original missions.
16. Does the pilot command the avoidance maneuver?
No. The separation decisions and maneuvers are performed automatically by the UAAN system. The pilot supervises the safety of the demonstration flight.
17. Then what is the pilot's role during the demonstration?
The pilot is responsible for overall flight safety and can intervene if necessary. However, UAAN's separation decisions and negotiation are performed automatically.
18. What happens when three drones approach at the same time?
Each drone can recognize multiple nearby drones and evaluate multiple potential conflicts at the same time. Therefore, UAAN separation is not limited to simple one-to-one avoidance.
19. What is different between separation involving two drones and three drones?
With three or more drones, the separation maneuver of one drone may affect its separation from another drone. Therefore, relationships with multiple nearby drones must be considered simultaneously.
20. What happens if one drone moves differently from what was expected?
The drones' status information is continuously updated. If another drone changes its movement, the new information is received and the separation situation is recalculated.
21. What happens if Well Separation is lost?
The system transitions from normal separation management to a more urgent safety response. The priority is to restore safe separation as quickly as possible.
22. How many drones did you test in the UND demonstration?
In the UND demonstration, we conducted flight tests with up to four UAAN-equipped drones.
23. Can this be used for BVLOS operations?
Yes. Direct cooperative communication between aircraft and early separation could become an important safety layer for future large-scale BVLOS operations.
24. What happens if GPS is unavailable?
Our current implementation uses GNSS-based positioning. If alternative navigation systems or onboard sensors can provide position information, they can be integrated with the system.
25. Is the minimum safe separation distance always the same?
No. The required separation distance can be configured according to aircraft performance, speed, operating environment, and mission conditions.
26. Can this be used in complex real-world airspace?
That is our goal. We are currently conducting flight demonstrations in controlled environments. We plan to gradually increase the number of drones and the complexity of the scenarios and expand toward real-world operations.
27. What exactly is the UAAN communication system used in the demonstration?
UAAN is a direct communication network between unmanned aircraft. Drones share information directly with each other without relying on base stations, servers, or central control.
28. Why do we need a communication system like UAAN?
In the future, many autonomous drones will share the same airspace. We need a way for drones to share information directly and cooperate with each other to maintain safe separation.
29. Why don't you use 5G or LTE?
5G and LTE depend on terrestrial communication infrastructure. UAAN uses direct air-to-air communication, so safety-related communication can be maintained independently of terrestrial network connectivity.
30. What is the communication range?
The target communication range is approximately 3 to 5 kilometers. The actual range may vary depending on the surrounding environment and antenna conditions.
31. What happens if communication is lost?
LTE communication in the air can become unstable due to temporary network congestion or interference between base stations. In contrast, a distributed wireless system like UAAN does not depend on base stations or a central network, so it is not affected by those types of network failures.
Except in unusual situations such as intentional jamming or equipment failure, UAAN is designed to maintain continuous direct communication. Temporary communication errors or packet loss may occur, but the system is designed to handle them. Equipment failure can also be addressed through redundant communication hardware.
32. Won't the network become congested when there are many drones?
UAAN is designed to prevent communication congestion even when hundreds of drones operate within a confined area. Scalability is a key design goal of UAAN.
33. Is UAAN internationally standardized?
Yes. The fundamental network architecture and communication concepts of UAAN have been internationally standardized in ISO/IEC 4005 Parts 1 through 4.
34. How is UAAN different from Remote ID?
Remote ID primarily provides drone identification and location information. UAAN goes further by allowing drones to directly share operational information and negotiate separation with each other.
35. How is UAAN different from ADS-B?
There are some similarities because both broadcast aircraft status information. However, UAAN is designed for unmanned aircraft operations and supports direct cooperative communication and separation negotiation between aircraft.
36. How is UAAN different from conventional drone DAA?
Conventional DAA relies heavily on sensors to detect other aircraft. UAAN adds cooperative communication, allowing drones to share not only where they are now, but also where they intend to go.
37. Does UAAN replace cameras or radar?
Not necessarily. UAAN can provide information between cooperative aircraft, while sensors such as cameras and radar can detect non-cooperative aircraft or obstacles. The technologies can complement each other.
38. Does UAAN compete with UTM?
No. UAAN can complement UTM rather than replace it. UTM can manage the overall airspace and traffic, while UAAN allows nearby aircraft to cooperate directly in real time.
39. Does UAAN work without an Internet connection?
Yes. Basic air-to-air safety communication does not require an Internet connection.
40. How do you address cybersecurity?
In actual operations, authentication, message integrity, and secure aircraft identification are important. These security features can be implemented while maintaining UAAN's distributed architecture.
41. When do you plan to commercialize the technology?
We are currently focused on validating the technology through actual flight tests and multi-drone demonstrations. The next step is to gradually integrate it with real-world operations and airspace management systems.
42. Do all drones need to be equipped with this device to achieve WS?
Yes. Drones need to be equipped with a UAAN device to recognize each other and maintain separation. Since UAAN is a communication device, it has significant advantages in size, weight, and cost for drone integration compared with systems based on radar or camera-based image processing.
43. What is the most important thing you want to demonstrate at UND?
The key point is simple: drones can communicate directly, detect potential conflicts early, negotiate separation with each other, and then safely continue their original missions.